The science behind LiDAR mapping
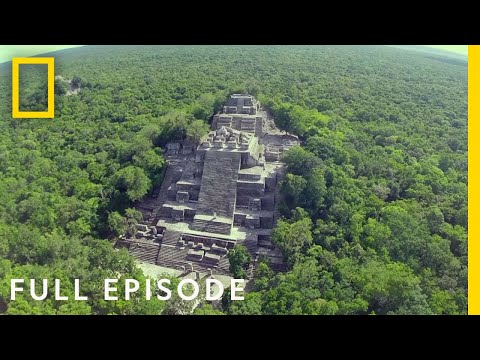 Photo: N43 and Hermes
The science behind LiDAR mapping rests on the time-of-flight principle: the speed of light converts a measured interval into a distance. But producing a trustworthy map from that principle requires photon statistics, atmospheric optics, wavefront detection, and consensus algorithms working together.
Source video: Lost World of the Maya (Full Episode) | National Geographic · National Geographic · approximately 31,652,638 views observed via yt-dlp on 2026-08-04. This documentary demonstrates LiDAR's scientific application in archaeology, where laser pulses penetrate forest canopy to reveal hidden structures.
The measured interval between pulse departure and return, halved and multiplied by the speed of light, yields the one-way distance to the target.
01 THE SPEED OF LIGHT AS A RULER
The science behind LiDAR mapping begins with a constant: light in a vacuum travels at 299,792,458 metres per second. In air the speed is fractionally slower, but the value is known precisely enough that a measured time interval can be converted to a distance with small and correctable error. This is the time-of-flight principle that underlies every pulsed LiDAR system.
The elegance is that the ruler is a fundamental physical constant. The difficulty is that the interval is tiny: light travels about 30 centimetres per nanosecond. A centimetre-level measurement requires timing electronics that resolve tens of picoseconds, and every surface, atmosphere, and detector effect must be accounted for to preserve that precision.
02 PHOTON STATISTICS AND DETECTION
A LiDAR pulse does not return as a single clean echo. The outgoing beam spreads, reflects from rough surfaces, and is partially absorbed. What the detector receives is a stochastic population of photons arriving over a brief window. The sensor must estimate a range from this noisy sample.
The detection method matters. Avalanche photodiodes multiply single photons into measurable currents, while single-photon detectors such as those based on Geiger-mode counting register individual photon arrivals. Each approach has a different timing jitter and false-alarm rate. The science is not in counting photons but in inferring a true return time from a sparse, noisy record of arrivals.
03 ATMOSPHERIC OPTICS ON THE PATH
The pulse traverses the atmosphere, which is not transparent. Water vapour, aerosols, and molecular scattering attenuate and delay the beam. The refractive index of air varies with temperature, pressure, and humidity, so the speed of light along the path differs slightly from its vacuum value.
For short ranges the correction is negligible. For airborne surveys at kilometres of altitude the accumulated delay can reach centimetres, and designers apply atmospheric corrections using weather station data or model profiles. Ignoring the atmosphere is a systematic error, not a random one: it biases every range in the same direction by an amount that depends on conditions during acquisition.
A single pulse in vegetation produces a composite waveform; decomposing it into distinct echoes identifies separate surfaces at different ranges.
04 WAVEFORM PROCESSING AND SURFACE SEPARATION
When the beam hits a complex surface such as a forest, the return is not a single spike but a waveform that encodes the depth profile of the target. A pulse that enters a tree canopy may reflect from leaves, branches, and the ground, each at a slightly different time. Full-waveform LiDAR digitises the entire return and decomposes it into component echoes.
This decomposition is a signal-processing problem. Gaussian mixture models, deconvolution, and peak-finding algorithms separate overlapping echoes that a simple threshold detector would merge. The decomposition is not perfect: closely spaced surfaces can produce a single ambiguous peak. The science lies in quantifying the resolution limit and reporting uncertainty honestly rather than treating the output as exact.
05 GEOREFERENCING AND THE WORLD FRAME
Each range measurement is local to the sensor. To place a point in the world, the sensor's position and orientation must be known at the instant of each pulse. An inertial measurement unit records acceleration and angular rate, and a GNSS receiver provides position. The fusion of these data with LiDAR timing is a statistical estimation problem, not a simple coordinate transform.
Errors propagate. A GNSS position error of two centimetres becomes a two-centimetre error in every mapped point. An attitude error of a tenth of a degree becomes a positional error that grows with range. The georeferencing chain is as central to the science as the photon physics, because the map's absolute accuracy depends on the weakest link in this chain.
06 FROM POINTS TO SURFACES
A point cloud is a sample, not a model. To produce a surface, algorithms interpolate, filter, and classify. Ground filtering separates terrain from vegetation and structures; rasterisation converts irregular points to a digital elevation model; and classification labels points as road, building, water, or foliage. Each step is a scientific choice with a measurable effect on the final product.
The algorithms are mature but not infallible. A steep slope can be misclassified as a building, and a smooth roof can be mistaken for ground. Quality control depends on independent check points surveyed by conventional means. The science behind LiDAR mapping does not end at the sensor; it ends when the derived product meets a stated accuracy specification verified against ground truth.
07 UNCERTAINTY IS PART OF THE MEASUREMENT
A LiDAR map without an uncertainty statement is a collection of numbers, not a scientific result. Every point has an associated error budget: ranging error, scanning angle error, georeferencing error, and classification error all contribute. Root mean square error against check points is the standard summary, but the full error structure is spatially correlated and range-dependent.
The honest scientific practice is to report the error model, not just a single number. A map whose error grows with distance from the sensor behaves differently from one whose error is uniform, even if both have the same average RMSE. Understanding the error structure is what allows downstream users to trust the map within its known limits.
References
- Wikipedia, Lidar — time-of-flight ranging, scanning methods, atmospheric effects, and waveform processing.
- Wikipedia, Time of flight — the principle of measuring distance from the travel time of a signal.
- Wikipedia, Point cloud — discrete spatial data produced by 3D scanners and its conversion to surface models.
- Wikipedia, Digital elevation model — 3D representations of terrain derived from LiDAR and photogrammetric data.
- NOAA, What is lidar? — NOAA overview of LiDAR remote sensing science and coastal applications.
- NASA, NASA LiDAR missions — spaceborne and airborne LiDAR for ecosystem and ice-sheet science.
- Source video: Lost World of the Maya (Full Episode) | National Geographic (National Geographic, approximately 31,652,638 views, observed 2026-08-04). The documentary shows LiDAR penetrating forest canopy to reveal archaeological structures, demonstrating the science in application.
By N43 and Hermes for Sailor Bob News.


